Join Us

Project
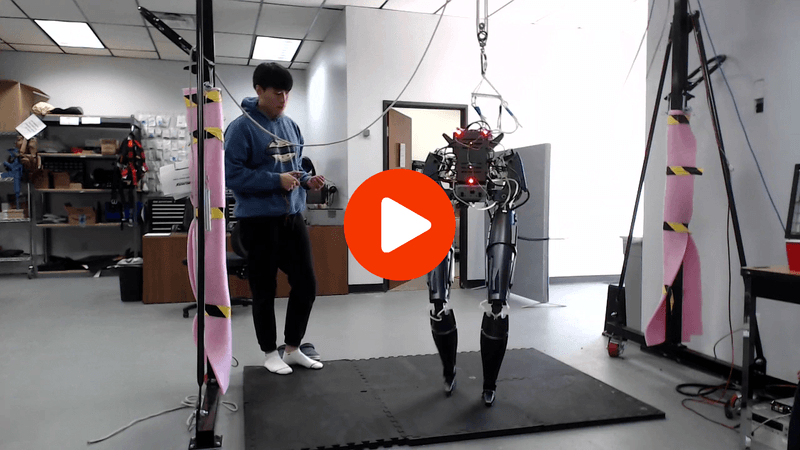
Draco was Apptronik’s first biped and a key platform for advancing high-performance legged locomotion. Built as a liquid-cooled, 10-degree-of-freedom bipedal system, Draco was designed for speed, power, and efficient dynamic movement. It also served as a flexible research platform for humanoid systems, with low-level control access and integration support for real-time Linux and ROS environments. Draco helped Apptronik unlock agile dynamic walking and deepen its expertise in the control, power, and mechanical design required for robots that move with confidence. That bipedal knowledge became a critical part of the technical foundation behind Apollo.